
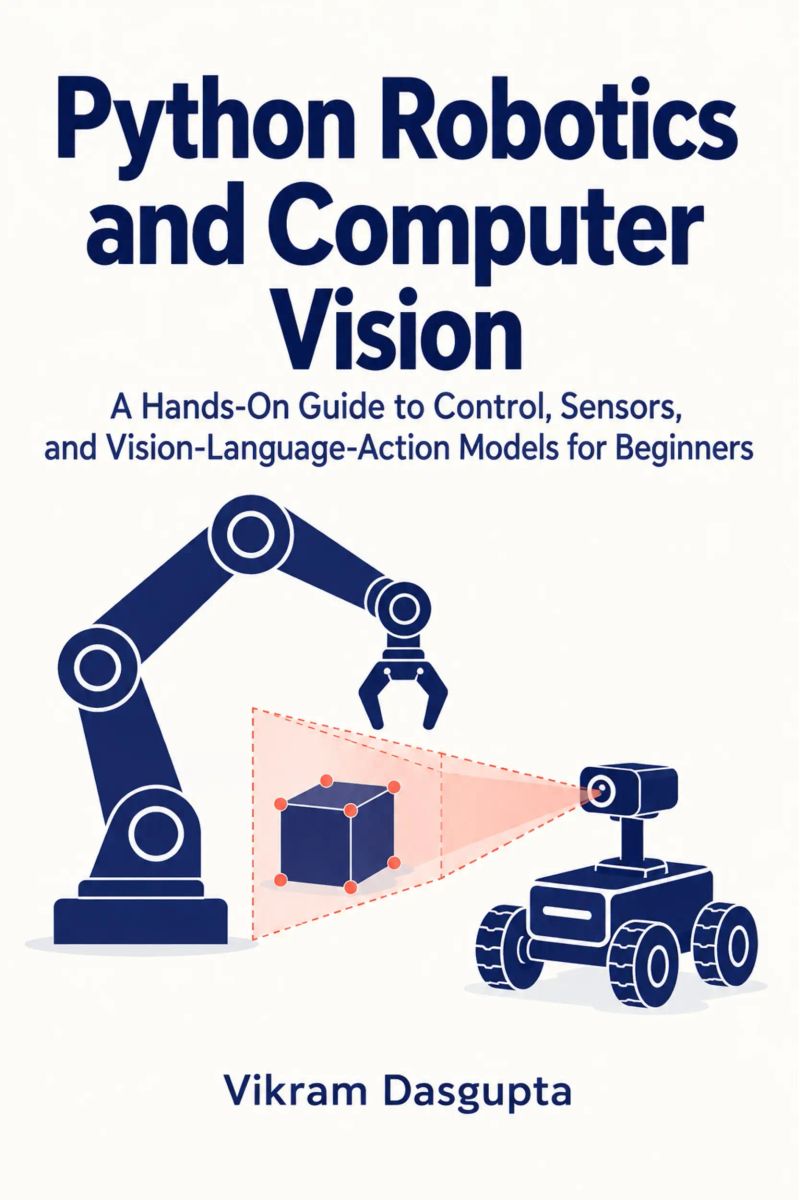
Python Robotics and Computer Vision
A Hands-On Guide to Control, Sensors, and Vision-Language-Action Models for BeginnersBy Vikram Dasgupta


Length11h 11m
About this audiobook
Build robots that see, think, and act — with Python as your only toolkit.
You want a robot that senses the world and acts on it, and you want to build it in Python. This hands-on guide starts with transforms and kinematics, then has you driving motors through tuned PID loops, fusing IMU and range data, and calibrating a camera properly before a single pixel is trusted. Every example runs in simulation first, so you can experiment safely before touching hardware.
From there you segment objects in OpenCV, estimate marker poses, run a neural detector on edge hardware, and close the loop with visual servoing and depth-camera grasping. Mapping, particle-filter localisation and path planning turn the robot loose, and the final chapter shows how vision-language-action policies and imitation learning fit alongside classical control. The progression is deliberate: each chapter builds on the last, moving from rigid-body math to a robot that can navigate a room and pick up an object it has never seen before.
What you will learn:
• Set up a complete Python robotics toolchain for simulation and real hardware
• Apply rigid-body transforms and arm kinematics to describe robot motion
• Drive wheeled mobile robots and tune PID loops with encoder feedback
• Fuse IMU and range data into a reliable state estimate
• Calibrate a camera and build classical vision pipelines in OpenCV
• Run deep vision detectors on edge hardware for real-time perception
• Implement visual servoing and depth-camera grasping
• Map an environment, localise with particle filters, and plan paths
• Understand how vision-language-action models and imitation learning complement classical control
For beginners, makers and engineering students taking their first serious step into robotics and machine vision, this book assumes only basic Python and a willingness to experiment. If you have ever wanted to move from blinking an LED to closing a perception-action loop, this is your starting point.
Audiobook details
GenreTechnology
Length11 hrs 11 mins
Narrated byListen with 1,000+ voices
FormateBook with Audio
Publish dateSep 27, 2026
LanguageEnglish
Table of contents
1Python Robotics and Computer Vision
2Foreword
3Preface
4About This Book
5Chapter 1: Setting Up the Robotics Toolchain
Show all chaptersShow less
61.1 Python, Virtual Environments, and Package Management
71.2 NumPy for Robot Mathematics
81.3 OpenCV and the Image Array
91.4 Robot Middleware and Message Passing
101.5 Choosing and Running a Physics Simulator
111.6 Project Layout, Version Control, and Reproducibility
12Chapter 2: Rigid-Body Transforms
132.1 Frames, Vectors, and Coordinate Conventions
142.2 Rotation Matrices in Two and Three Dimensions
152.3 Homogeneous Transforms and Composition
162.4 Euler Angles and Their Pitfalls
172.5 Quaternions and Smooth Rotation
182.6 Transform Trees and Frame Bookkeeping
19Chapter 3: Arm Kinematics
203.1 Joint Types, Links, and the Kinematic Chain
213.2 Denavit-Hartenberg Parameters and Forward Kinematics
223.3 Workspace, Reachability, and Singular Configurations
233.4 The Jacobian and Differential Motion
243.5 Numerical Inverse Kinematics
25Chapter 4: Wheeled Mobile Robots
264.1 Differential-Drive Geometry and the Instantaneous Model
274.2 Wheel Odometry and Pose Integration
284.3 Dead-Reckoning Error and Its Growth
294.4 Ackermann and Omnidirectional Bases
30Chapter 5: Motors, Encoders, and PID Control
315.1 DC Motors, Drivers, and the Command Interface
325.2 Encoders and Velocity Estimation
335.3 The PID Control Law
345.4 Tuning the Loop
355.5 Feedforward, Anti-Windup, and the Serial Link
36Chapter 6: Sensors and State Estimation
376.1 Inertial Measurement Units
386.2 Range Sensors: Ultrasonic and LiDAR
396.3 The Complementary Filter
406.4 The Kalman Filter
416.5 Fusing Odometry with Heading and Range
42Chapter 7: Image Formation and Camera Calibration
437.1 The Pinhole Model and the Camera Matrix
447.2 Lens Distortion and Its Correction
457.3 Checkerboard Calibration
467.4 Extrinsics and the Camera-to-Robot Transform
47Chapter 8: Classical Vision Pipelines in OpenCV
488.1 Color Spaces and Segmentation
498.2 Contours, Moments, and Shape Features
508.3 Edges, Lines, and Feature Points
The Honey BusMeredith May9h 31m4.4 (16.6K)$25 · $0.00
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
Operation PedestalMax Hastings12h 29m4.4 (5.2K)$29 · $0.00
When the Heavens Went on SaleAshlee Vance18h 20m4.4 (3K)$40 · $0.00
Everybody Has a Podcast (Except You)Justin McElroy, Travis McElroy, Griffin McElroy5h 9m4.3 (2.3K)$24 · $0.00
Hands of TimeRebecca Struthers8h 8m4.4 (1.3K)$26 · $0.00
Never Lost AgainBill Kilday10h 1m4.4 (805)$29 · $0.00
How the Internet HappenedBrian McCullough13h 28m4.3 (2.7K)$23 · $0.00
Collected Writings of Nikola TeslaNikola Tesla, Thomas Commerford Martin21h 50m4.3 (1.7K)$1 · $0.00
Just AspireAjai Chowdhry9h 13m4.4 (260)$29 · $0.00
The Little Book of AliensAdam Frank8h 20m4.3 (1.3K)$26 · $0.00
The inventions, researches and writings of Nikola Tesla (Annotated)Thomas Commerford Martin16h 59m4.3 (1.3K)$2 · $0.00
KargilV.P. Malik15h 18m4.3 (2K)$24 · $0.00
Experiments with Alternating CurrentsNikola Tesla9h 16m4.3 (874)$1.99 · $0.00
Fire on the HorizonTom Shroder, John Konrad8h 23m4.3 (858)$26 · $0.00
The Smell of Kerosene (Annotated)National Aeronautics and Space Administration, Donald L. Mallick, Peter W. Merlin11h 32m4.3 (523)$2 · $0.00
The Boy Who Harnessed the WindWilliam Kamkwamba, Bryan Mealer10h 5m4.2 (78.9K)$29 · $0.00
Across the Airless WildsEarl Swift10h 8m4.3 (1.3K)$29 · $0.00
Console WarsBlake J. Harris20h 41m4.2 (13.7K)$46 · $0.00
Improvised Munitions HandbookU.S. Department of Defense4h 49m4.3 (1.6K)$0.99 · $0.00
You may also like
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
Robotics Mechanisms and Embedded ControlTomas Belmonte15h 11m$90
C++ for RoboticsEsther Underwood7h 21m$5 · $0.00
Build Intelligent SystemsNathan Underwood7h 15m$5 · $0.00
Artificial Intelligence for Game DevelopmentTheo Riven4h 41m$5
Signal Processing for Electrical EngineersHelen Marchetti12h 6m$80
Grundlagen der 3D-Computer Vision Tiefenschätzung, Punktwolkenverarbeitung und Volumetrische Rekonstruktion aus KameraanordnungenSloane Garrett7h 59m$13 · $0.00
C++ Programming for Natural Language ProcessingTheo Riven5h 6m$5
Build with Agentic AIDaria Quill7h 21m$5
Edge-AI-Engineering Wie man Künstliche Intelligenz am Netzwerkrand Aufbaut, Bereitstellt und OptimiertSloane Garrett6h 33m$13 · $0.00
Eft Investing: A Comprehensive Guide to Researching and Investing (The Intelligent Investor's Guide to Using Free Online Stock Screeners to Find Winning Stocks)Matthew Nagel2h 7m$3.50 · $0.00
Artificial Intelligence for IoT Development SubtitleTheo Riven3h 54m$5
Tech of TomorrowJulie Murray18m$3
Decoding DCFPenelope B. Wellington7h 36m$6.30 · $0.00
EFT Investing: A Comprehensive Guide to Understanding Real Estate Syndications Accredited Investor Banking (A Complete Guide to Options Trading Binary Options Stock Options Currency Index Options EFT)Charles Thompson2h 34m$3.50 · $0.00
Master AiHenrique Xavier Oliveira2h 5m$6 · $0.00
No-Code AI AgentsVincent Abara7h 37m$5 · $0.00
Universe And RealityAlder D'pass2h$7 · $0.00
Law of Startups in Brazil and the WorldVitor Mendonça Prado3h 51m$12 · $0.00
The Physics of EvidenceShannon W. Bray6h 10m4.3 (11)$19.99