
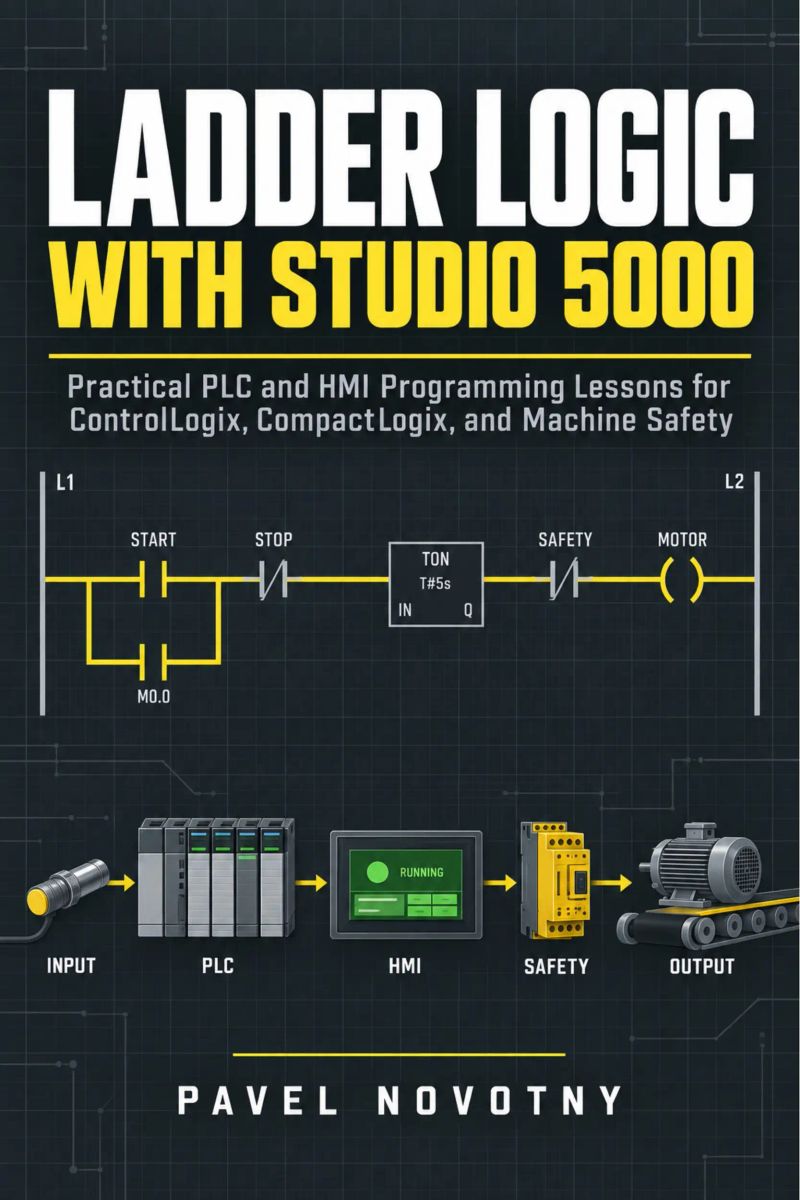
Ladder Logic with Studio 5000
Practical PLC and HMI Programming Lessons for ControlLogix, CompactLogix, and Machine SafetyBy Pavel Novotny


Length14h 54m
About this audiobook
Rungs are easy to copy and hard to trust. This book teaches you to write logic you can commission and hand over.
Most PLC knowledge is passed around as screenshots and tribal memory. This book replaces that with a structured path through Studio 5000, from controller selection and project organisation to the scan cycle, tag architecture, and machine safety. You will configure a controller, set a communication path, go online, and build a tag structure with user-defined types and aliases that still makes sense a year later. The emphasis throughout is on logic that can be read, tested, and maintained by someone other than its author.
You will write seal-in motor circuits with correct stop priority, apply on-delay, off-delay and retentive timers to conveyor and dwell problems, scale analog inputs from raw counts to engineering units, and tune a process loop without integral windup. Later chapters cover task structure and scan behaviour, industrial Ethernet, produced and consumed tags, drive control, reusable add-on instructions, safety controller logic for emergency stops, guard doors and light curtains, and operator screen, alarm and commissioning work. Each topic is tied to the practical decisions a controls engineer or maintenance technician makes on the plant floor.
What you will learn:
• Select and configure ControlLogix and CompactLogix hardware, then create a project and go online with a communication path
• Build tag structures with user-defined types and aliases that remain readable across the life of a machine
• Write bit instructions and seal-in motor control logic with correct stop priority and safe restart behaviour
• Apply timers and counters to conveyor, dwell, and sequencing problems, including retentive and off-delay cases
• Use compare, math, move, and array instructions to process data and handle recipes and part tracking
• Structure tasks, programs, and routines, and understand how scan behaviour affects logic execution
• Configure I/O and scale analog inputs from raw counts to engineering units
• Tune process loops and avoid integral windup in flow, pressure, and temperature control
• Implement industrial Ethernet, produced and consumed tags, and drive control between controllers
• Create reusable add-on instructions and structured text, and apply safety controller logic for emergency stops, guard doors, and light curtains
• Design HMI screens, alarms, and commissioning and troubleshooting workflows
Written for maintenance technicians, controls engineers, and automation students, this book assumes you want to move beyond copying rungs to writing logic you can defend. If you work with Rockwell Automation platforms and need a practical reference that connects programming decisions to commissioning and handover, this is for you.
Audiobook details
GenreTechnology
Length14 hrs 54 mins
Narrated byListen with 1,000+ voices
FormateBook with Audio
Publish dateSep 27, 2026
LanguageEnglish
Table of contents
1Ladder Logic with Studio 5000
2Foreword
3Preface
4About This Book
5Important Safety Notice
Show all chaptersShow less
6Chapter 1: Controller Hardware and Platform Selection
71.1 What a Programmable Controller Does on a Packaging Line
81.2 Chassis-Based ControlLogix Hardware
91.3 Compact Controllers and When They Fit Better
101.4 Digital, Analog, Relay and Specialty Modules
111.5 Power Supplies, Wiring Arms and Termination
121.6 Choosing a Platform for a Machine
13Chapter 2: Projects, the Controller Organiser and Going Online
142.1 Creating a Project and Setting Controller Properties
152.2 The Controller Organiser and Its Folders
162.3 Communication Paths and Driver Setup
172.4 Downloading, Uploading and Going Online
182.5 Online Edits, Backup and Revision Discipline
19Chapter 3: Tags, Data Types and Structures
203.1 Controller Scope and Program Scope
213.2 Atomic Data Types: Boolean, Integer and Real
223.3 Timers and Counters as Structures
233.4 User-Defined Data Types
243.5 Arrays and Indexed Access
253.6 Aliases and a Naming Convention That Survives Handover
26Chapter 4: Bit Instructions and Motor Control Logic
274.1 Examine If Closed, Examine If Open and Output Energise
284.2 Latch, Unlatch and One-Shot Instructions
294.3 Stop-Priority and Fail-Safe Wiring
304.4 Seal-In Motor Circuits
314.5 Permissives, Interlocks and First-Out Indication
32Chapter 5: Timers and Counters
335.1 On-Delay Timers
345.2 Off-Delay Timers
355.3 Retentive Timers and Dwell Control
365.4 Up Counters and Part Counting
375.5 Down Counters, Cascades and Batch Totals
38Chapter 6: Compare, Math, Move and Array Instructions
396.1 Equality, Limit and Comparison Tests
406.2 Arithmetic and Compute Instructions
416.3 Move and Masked Move
426.4 Copy, Fill and Array Handling
436.5 Recipe Handling with Arrays and Indexed Addressing
44Chapter 7: Tasks, Programs, Routines and Scan Behaviour
457.1 Continuous, Periodic and Event Tasks
467.2 Programs, Routines and Subroutine Calls
477.3 Scan Order and Logic Placement
487.4 Execution Time Budgeting
49Chapter 8: Input and Output Configuration and Analog Scaling
508.1 Module Properties, Connection Types and Requested Packet Interval
Hands of TimeRebecca Struthers8h 8m4.4 (1.3K)$26 · $0.00
Never Lost AgainBill Kilday10h 1m4.4 (805)$29 · $0.00
How the Internet HappenedBrian McCullough13h 28m4.3 (2.7K)$23 · $0.00
Collected Writings of Nikola TeslaNikola Tesla, Thomas Commerford Martin21h 50m4.3 (1.7K)$1 · $0.00
Just AspireAjai Chowdhry9h 13m4.4 (260)$29 · $0.00
The Little Book of AliensAdam Frank8h 20m4.3 (1.3K)$26 · $0.00
The inventions, researches and writings of Nikola Tesla (Annotated)Thomas Commerford Martin16h 59m4.3 (1.3K)$2 · $0.00
KargilV.P. Malik15h 18m4.3 (2K)$24 · $0.00
Experiments with Alternating CurrentsNikola Tesla9h 6m4.3 (874)$1 · $0.00
Fire on the HorizonTom Shroder, John Konrad8h 23m4.3 (858)$26 · $0.00
The Smell of Kerosene (Annotated)National Aeronautics and Space Administration, Donald L. Mallick, Peter W. Merlin11h 32m4.3 (523)$2 · $0.00
The Boy Who Harnessed the WindWilliam Kamkwamba, Bryan Mealer10h 5m4.2 (78.9K)$29 · $0.00
Across the Airless WildsEarl Swift10h 8m4.3 (1.3K)$29 · $0.00
Console WarsBlake J. Harris20h 41m4.2 (13.7K)$46 · $0.00
Improvised Munitions HandbookU.S. Department of Defense4h 49m4.3 (1.6K)$1.99 · $0.00
Escaping GravityLori Garver10h 54m4.2 (2.2K)$20 · $0.00
Wireless WarsJonathan Pelson8h 2m4.3 (418)$20 · $0.00
Let There Be WaterSeth M. Siegel8h 36m4.2 (2.3K)$20 · $0.00
The PerfectionistsSimon Winchester11h 46m4.2 (9.9K)$29 · $0.00
Rethinking NarcissismDr. Craig Malkin6h 7m4.2 (3.4K)$24 · $0.00
You may also like
I am learning PunjabiJM Gardner3h 55m4.4 (113)$18 · $0.00
Triple Your Personal ProductivitySteve Pavlina13m4.0 (158)$4 · $0.00
Structural Vibrations and WavesNoriko Takasugi13h 58m$90
Materials Science and Engineering PrinciplesViktor Lindqvist15h 33m$95
How to Make Money Flipping Fitness Equipment - How to Source Bulky Gear Below Market Value, Refurbish It, and Profit from Local DemandJACK FLIPWELL8h 23m$7.90 · $0.00
ARE 5.0 Architect Registration Exam Study GuideMarie Peterson10h 1m$10
An Introduction to Machine Drawing and DesignDavid Allan Low3h 13m$2 · $0.00
Gas Burners Old and NewOwen Merriman3h 1m$2 · $0.00
Early Printed BooksE. Gordon Duff5h 1m3.6 (19)$2 · $0.00
Tower's Little Primer, for the youngest class in primary schoolAnna E. Tower9m$2 · $0.00
A complete guide drawing to for children aged 5-10Liliana Grisa, Matteo Viganò16m$9 · $0.00
The Silversmith's Handbook (Annotated)George E. Gee5h 19m$2 · $0.00
Disc GolfHarper B. Montgomery2h 50m$2.30 · $0.00
SoftballMarcus B. Cole31m$2.30 · $0.00
Activity-Based Budgeting UncoveredLuna Z. Rainstorm9h 38m$6.40 · $0.00
An Interactive In-Depth Study Guide to The Audacity ExperimentVere Bates1m$10.50 · $0.00
AP Chemistry Exam Study GuideMarie Peterson8h 41m$10
AP Physics 1 Exam Study GuideMarie Peterson9h 31m$10
Competitive Programming in C++Tessa Larkin7h 44m$5 · $0.00
Arduino Electronics with CMarisol Vasquez7h 17m$5 · $0.00