
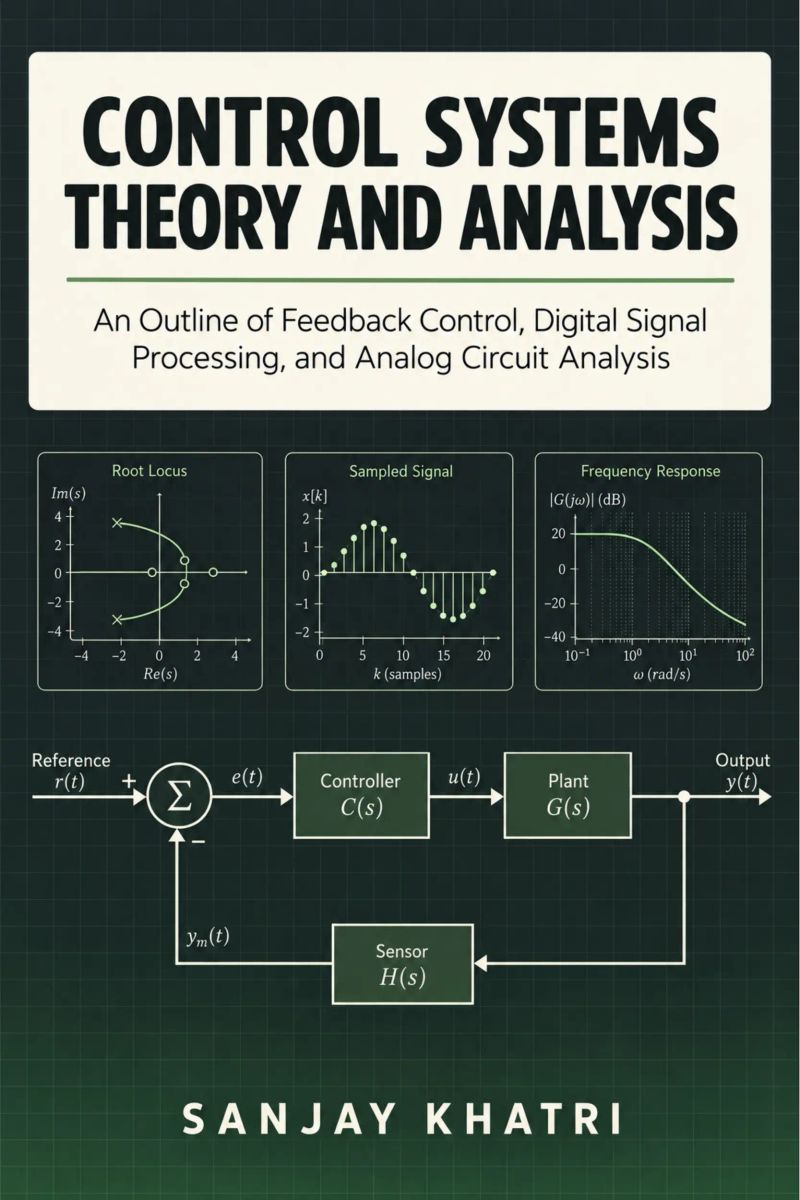
Control Systems Theory and Analysis
An Outline of Feedback Control, Digital Signal Processing, and Analog Circuit AnalysisBy Sanjay Khatri


Length12h 5m
About this audiobook
Most control texts bury the idea under transform algebra. This one tells you what each plot means before it derives anything.
Control Systems Theory and Analysis is a working outline of feedback control, digital signal processing and analog circuit analysis, written for readers who want to understand what a control system is doing before they wrestle with the mathematics behind it. The book opens with the circuit analysis and op-amp building blocks you need to model real hardware, then builds transfer functions and reads time-domain responses in terms of damping, overshoot and settling time. Stability is introduced through Routh-Hurwitz and pole locations, steady-state error through system type, and design through root locus, Bode plots, gain and phase margin and the Nyquist criterion.
From there the book moves into practical compensation: lead, lag and PID tuning, with windup and derivative-filtering fixes that matter when a controller meets a real plant. The later chapters extend the same ideas into state-space pole placement, observers, sampling, the z-transform and digital filtering. A single motor loop runs through every method, so you can compare designs honestly instead of learning each technique in isolation.
What you will learn:
• Circuit analysis and analog building blocks, including op-amp configurations used to model real hardware
• Laplace transforms, transfer functions and the modelling of physical systems
• Time-domain response: damping, overshoot, rise time and settling time
• Stability by Routh-Hurwitz and pole location, and steady-state error by system type
• Root locus, frequency response, Bode plots, gain and phase margin, and the Nyquist criterion
• Lead, lag and PID compensation, including windup and derivative-filtering fixes
• State-space methods: pole placement and observer design
• Sampling, the z-transform and digital control loops
• Digital signal processing techniques applied to control systems
Written for electrical and mechanical engineering students and for self-taught engineers who want a clear, method-by-method outline they can return to while studying or designing, this book keeps the focus on what each tool tells you about a system and when to reach for it.
Audiobook details
GenreTechnology
Length12 hrs 5 mins
Narrated byListen with 1,000+ voices
FormateBook with Audio
Publish dateSep 28, 2026
LanguageEnglish
Table of contents
1Control Systems Theory and Analysis
2Foreword
3Preface
4About This Book
5Chapter 1: Circuit Analysis You Actually Need
Show all chaptersShow less
61.1 Charge, Current, Voltage and the Sign Rules
71.2 Kirchhoff’s Laws and Node Analysis
81.3 Mesh Analysis and Source Transformation
91.4 Thevenin and Norton Equivalents
101.5 Phasors, Impedance and AC Power
111.6 Measurement, Loading and Practical Limits
12Chapter 2: Analog Building Blocks
132.1 The Ideal Op-Amp and the Two Golden Rules
142.2 Inverting, Non-Inverting and Differential Configurations
152.3 Integrators, Differentiators and the Analog PID Skeleton
162.4 Passive and Active Filters
172.5 RC, RL and RLC Transients and Resonance
18Chapter 3: Laplace Transforms and Transfer Functions
193.1 Definition, Transform Pairs and Properties
203.2 Inverse Transforms by Partial Fractions
213.3 Transfer Functions, Poles and Zeros
223.4 The DC Motor Position Loop as a Running Example
233.5 Initial and Final Value Checks and Model Sanity
24Chapter 4: Modelling Physical Systems
254.1 Electrical Networks as LTI Systems
264.2 Translational and Rotational Mechanics
274.3 Thermal and Fluid Models
284.4 Block Diagram Algebra and Signal Flow Graphs
294.5 Disturbances, Noise Injection and Model Uncertainty
30Chapter 5: Time-Domain Response
315.1 First-Order Response and the Time Constant
325.2 Second-Order Response, Damping and Natural Frequency
335.3 Specifications: Rise Time, Overshoot, Settling Time
345.4 Dominant Poles, Zeros and Model Reduction
35Chapter 6: Stability
366.1 Bounded-Input Bounded-Output Stability
376.2 The Routh-Hurwitz Criterion
386.3 Stability of the Motor Position Loop with Proportional Gain
396.4 Relative Stability and the Distance to the Boundary
40Chapter 7: Steady-State Error
417.1 System Type and the Error Constants
427.2 Disturbance Rejection and Error from Reference and Load
437.3 Integral Action and Error Elimination
44Chapter 8: Root Locus
458.1 The Root Locus Equation and Basic Rules
468.2 Asymptotes, Breakaway Points and Departure Angles
478.3 Designing Gain for a Damping Specification
48Chapter 9: Frequency Response and Bode Plots
499.1 Sinusoidal Steady-State Response and the Frequency Response Function
509.2 Bode Magnitude and Phase Asymptotes
The Honey BusMeredith May9h 31m4.4 (16.6K)$25 · $0.00
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
Operation PedestalMax Hastings12h 29m4.4 (5.2K)$29 · $0.00
When the Heavens Went on SaleAshlee Vance18h 20m4.4 (3K)$40 · $0.00
Everybody Has a Podcast (Except You)Justin McElroy, Travis McElroy, Griffin McElroy5h 9m4.3 (2.3K)$24 · $0.00
Hands of TimeRebecca Struthers8h 8m4.4 (1.3K)$26 · $0.00
Never Lost AgainBill Kilday10h 1m4.4 (805)$29 · $0.00
How the Internet HappenedBrian McCullough13h 28m4.3 (2.7K)$23 · $0.00
Collected Writings of Nikola TeslaNikola Tesla, Thomas Commerford Martin21h 50m4.3 (1.7K)$1 · $0.00
Just AspireAjai Chowdhry9h 13m4.4 (260)$29 · $0.00
The Little Book of AliensAdam Frank8h 20m4.3 (1.3K)$26 · $0.00
The inventions, researches and writings of Nikola Tesla (Annotated)Thomas Commerford Martin16h 59m4.3 (1.3K)$2 · $0.00
KargilV.P. Malik15h 18m4.3 (2K)$24 · $0.00
Experiments with Alternating CurrentsNikola Tesla9h 16m4.3 (874)$1.99 · $0.00
Fire on the HorizonTom Shroder, John Konrad8h 23m4.3 (858)$26 · $0.00
The Smell of Kerosene (Annotated)National Aeronautics and Space Administration, Donald L. Mallick, Peter W. Merlin11h 32m4.3 (523)$2 · $0.00
The Boy Who Harnessed the WindWilliam Kamkwamba, Bryan Mealer10h 5m4.2 (78.9K)$29 · $0.00
Across the Airless WildsEarl Swift10h 8m4.3 (1.3K)$29 · $0.00
Console WarsBlake J. Harris20h 41m4.2 (13.7K)$46 · $0.00
Improvised Munitions HandbookU.S. Department of Defense4h 49m4.3 (1.6K)$1.99 · $0.00
You may also like
ITIL Foundation Essentials ITIL 4 Edition - The ultimate revision guide, second editionClaire Agutter1h 12m4.2 (462)$27 · $0.00
Pete the Cat: Robo-PeteJames Dean5m4.0 (2.3K)$4 · $0.00
Machines of Loving GraceJohn Markoff11h 53m3.8 (1.4K)$29 · $0.00
AutonomyLawrence D. Burns, Christopher Shulgan11h 21m4.1 (1.1K)$29 · $0.00
The Highway Code UKDepartment for Transport3h 33m4.2 (36.6K)$11 · $0.00
C++ for RoboticsEsther Underwood7h 21m$5 · $0.00
Computers The Machines We Think WithD. S. Halacy8h 40m3.5 (10)$2.30
Hollyweird Science: The Next GenerationKevin R. Grazier, Stephen Cass16h 50m3.5 (15)$25
Machines at WorkMary Elting37m3.9 (18)$2 · $0.00
Where's My Jetpack?Daniel H. Wilson3h 41m3.5 (935)$12 · $0.00
Signal Processing for Electrical EngineersHelen Marchetti12h 6m$80
THE COMPLETE HANDBOOK OF MECHANICAL ENGINEERINGMICHAEL DURAN4h 12m$10.50 · $0.00
Build with Agentic AIDaria Quill7h 21m$5
Build AI Agents with FlowiseCyrus Fontaine8h 1m$5
Build Language Models with PythonEsther Fontaine7h 32m$5
THE RISE OF PHYSICAL AI and HUMANOIDSGathu Kamau2h 59m4.7 (134)$4.99 · $0.00
Amazing Tales Volume 136Edmond Hamilton3h 26m$2.30
Automate Real Work with AILena Devlin7h 30m$5 · $0.00
DriverlessHod Lipson, Melba Kurman9h 57m3.9 (552)$20
Edge-AI-Engineering Wie man Künstliche Intelligenz am Netzwerkrand Aufbaut, Bereitstellt und OptimiertSloane Garrett6h 33m$13 · $0.00