
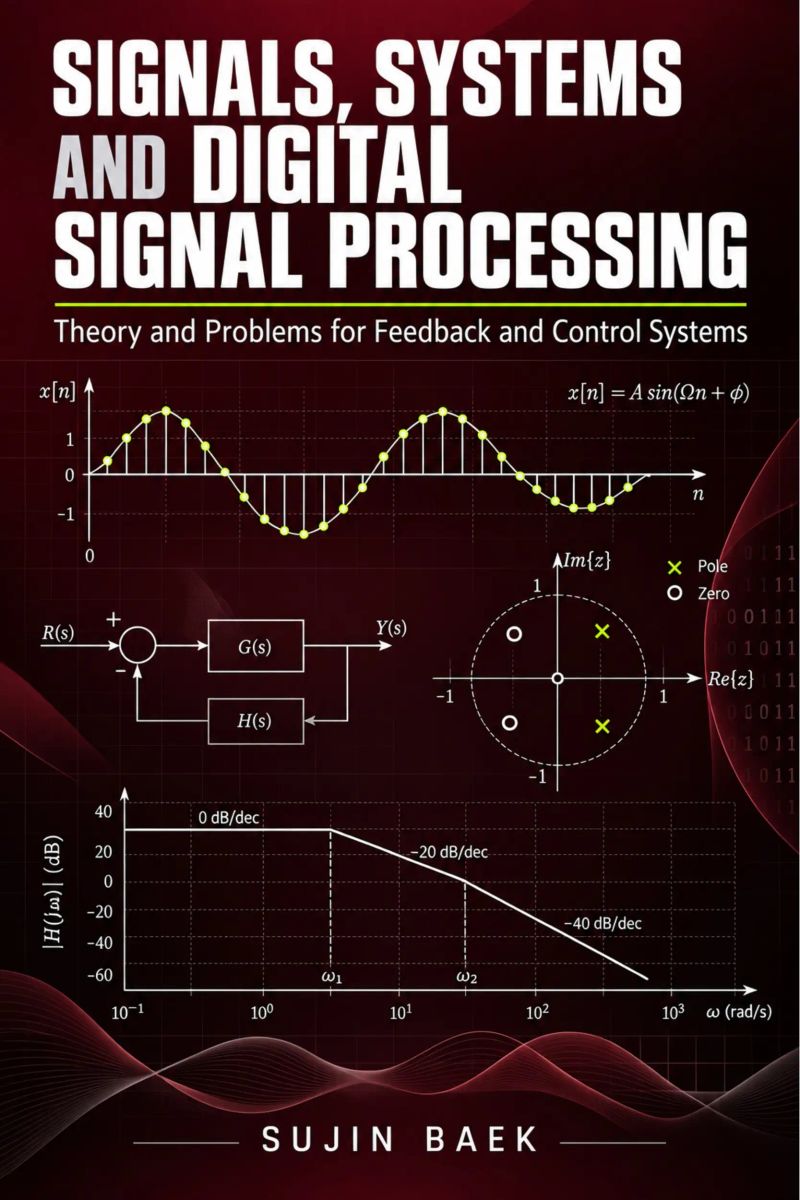
Signals, Systems and Digital Signal Processing
Theory and Problems for Feedback and Control SystemsBy Sujin Baek


Length13h 17m
About this audiobook
A unified, problem-solving guide that connects continuous and discrete signal processing with feedback and control systems, featuring fully solved problems and consistent notation.
Audiobook details
GenreTechnology, Science and Nature
Length13 hrs 17 mins
Narrated byListen with 1,000+ voices
FormateBook with Audio
Publish dateSep 27, 2026
LanguageEnglish
Table of contents
1Foreword
2Preface
3About This Book
4Chapter 1: Signals and Their Classification
51.1 Signals, Systems and the Language of This Book
Show all chaptersShow less
61.2 Continuous-Time and Discrete-Time Signals
71.3 Periodicity, Even and Odd Symmetry
81.4 Singularity Functions: Impulse, Step and Ramp
91.5 Time Shifting, Scaling and Reflection
101.6 Energy, Power and Average Value
11Chapter 2: Linear Time-Invariant Systems
122.1 System Properties: Linearity, Time Invariance, Memory, Causality, Stability
132.2 The Impulse Response and the Convolution Integral
142.3 Graphical Convolution and the Flip-and-Slide Method
152.4 The Convolution Sum
162.5 System Interconnection and Step Response
17Chapter 3: Differential and Difference Equations
183.1 Continuous-Time Differential Equations and the Natural Response
193.2 Particular Solutions and the Total Response
203.3 Zero-Input and Zero-State Decomposition
213.4 Difference Equations and Their Solution
223.5 Stability from Root Location
23Chapter 4: Fourier Series
244.1 Trigonometric and Exponential Forms
254.2 Symmetry Properties and Coefficient Shortcuts
264.3 Amplitude and Phase Spectra, and Parseval’s Relation
274.4 The Gibbs Phenomenon and Convergence
284.5 Steady-State Response to Periodic Inputs
29Chapter 5: The Fourier Transform
305.1 Definition, Convergence and Standard Transforms
315.2 Properties: Linearity, Shifting, Scaling, Duality, Modulation
325.3 Convolution and Parseval in the Frequency Domain
335.4 Frequency Response, Magnitude and Phase
345.5 Ideal and Practical Filters, and Amplitude Modulation
35Chapter 6: The Laplace Transform
366.1 Definition, Region of Convergence and Standard Pairs
376.2 Properties and the Initial and Final Value Theorems
386.3 Inversion by Partial Fractions
396.4 Transfer Functions, Poles and Zeros
406.5 Circuit Analysis with the Laplace Transform
41Chapter 7: Sampling and Reconstruction
427.1 The Sampling Theorem and Spectral Replication
437.2 Aliasing and Folding
447.3 Reconstruction: Ideal Interpolation and the Zero-Order Hold
457.4 Quantisation, Quantisation Noise and Converter Budgets
46Chapter 8: The z-Transform
478.1 Definition, Region of Convergence and Standard Pairs
488.2 Properties and the System Function
498.3 Inversion by Partial Fractions, Long Division and Residues
508.4 Stability, Causality and Pole Location
The Honey BusMeredith May9h 31m4.4 (16.6K)$25 · $0.00
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
Operation PedestalMax Hastings12h 29m4.4 (5.2K)$29 · $0.00
When the Heavens Went on SaleAshlee Vance18h 20m4.4 (3K)$40 · $0.00
Everybody Has a Podcast (Except You)Justin McElroy, Travis McElroy, Griffin McElroy5h 9m4.3 (2.3K)$24 · $0.00
Hands of TimeRebecca Struthers8h 8m4.4 (1.3K)$26 · $0.00
Never Lost AgainBill Kilday10h 1m4.4 (805)$29 · $0.00
How the Internet HappenedBrian McCullough13h 28m4.3 (2.7K)$23 · $0.00
Collected Writings of Nikola TeslaNikola Tesla, Thomas Commerford Martin21h 50m4.3 (1.7K)$1 · $0.00
Just AspireAjai Chowdhry9h 13m4.4 (260)$29 · $0.00
The Little Book of AliensAdam Frank8h 20m4.3 (1.3K)$26 · $0.00
The inventions, researches and writings of Nikola Tesla (Annotated)Thomas Commerford Martin16h 59m4.3 (1.3K)$2 · $0.00
KargilV.P. Malik15h 18m4.3 (2K)$24 · $0.00
Experiments with Alternating CurrentsNikola Tesla9h 16m4.3 (874)$1.99 · $0.00
Fire on the HorizonTom Shroder, John Konrad8h 23m4.3 (858)$26 · $0.00
The Smell of Kerosene (Annotated)National Aeronautics and Space Administration, Donald L. Mallick, Peter W. Merlin11h 32m4.3 (523)$2 · $0.00
The Boy Who Harnessed the WindWilliam Kamkwamba, Bryan Mealer10h 5m4.2 (78.9K)$29 · $0.00
Across the Airless WildsEarl Swift10h 8m4.3 (1.3K)$29 · $0.00
Console WarsBlake J. Harris20h 41m4.2 (13.7K)$46 · $0.00
Improvised Munitions HandbookU.S. Department of Defense4h 49m4.3 (1.6K)$1.99 · $0.00
A Brief History of IntelligenceMax S. Bennett12h 18m4.6 (6.6K)$29 · $0.00
The Story of BirdsSteve Brusatte11h 49m4.6 (401)$29 · $0.00
BeyondStephen Walker15h 39m4.6 (3.2K)$33 · $0.00
LiftoffEric Berger9h 4m4.6 (9.5K)$29 · $0.00
Black Earth WisdomLeah Penniman11h 54m4.6 (577)$8 · $0.00
Total Cat MojoJackson Galaxy10h 13m4.5 (8.4K)$23 · $0.00
My Life Among the UnderdogsTia Torres5h 51m4.5 (4K)$24 · $0.00
What It Takes to Save a LifeKwane Stewart6h4.6 (556)$24 · $0.00
Pastoral SongJames Rebanks8h 35m4.5 (12K)$26 · $0.00
How Stella Learned to TalkChristina Hunger7h4.5 (10.9K)$24 · $0.00
Craig & FredCraig Grossi8h 6m4.5 (9.6K)$26 · $0.00
Celebrating BirdsNatalia Rojas, Ana Maria Martinez6h 47m4.6 (330)$24 · $0.00
Saving JemimaJulie Zickefoose4h 59m4.5 (749)$20 · $0.00
Will's Red CoatTom Ryan8h 23m4.5 (2.3K)$26 · $0.00
Of Time and TurtlesSy Montgomery10h 34m4.5 (5K)$29 · $0.00
THE WOLF TRILOGY: Call of the Wild, White Fang & The Son of the WolfJack London17h 31m4.5 (2.4K)$1.99 · $0.00
Zen and the Art of Saving the PlanetThich Nhat Hanh9h 20m4.5 (3.9K)$29 · $0.00
BLACK BEAUTY (With Original Illustrations)Anna Sewell7h 31m4.5 (1.3K)$1.99 · $0.00
Bottle of LiesKatherine Eban14h 25m4.4 (12K)$33 · $0.00
IngrainedCallum Robinson8h 10m4.5 (1.1K)$26 · $0.00
You may also like
Taoist Teachings From the Book of Lieh TzŭLie Yukou2h 40m4.2 (1.3K)$1 · $0.00
The Art of Horse-Shoeing: A Manual for FarriersWilliam Hunting2h 58m4.6 (33)$1.50 · $0.00
How to Choose the Right Formula for Your BabyAurora Brooks1h 2m$3.50 · $0.00
COLORADO MOTORCYCLE PERMIT EXAM PREP 2026–2027Tyler Knox9h 9m$10
On the Execution of Music, and Principally of Ancient MusicCamille Saint-Saëns34m$1 · $0.00
Elements of Foreign Exchange: A Foreign Exchange PrimerFranklin Escher3h 36m4.1 (11)$1 · $0.00
Even IfBill Brown Jr.55m$5
Natural Stability and the Parachute Principle in AeroplanesW. LeMaitre2m$2 · $0.00
PunctuationFrederick W. Hamilton1h 36m$2 · $0.00
From Chess to CourtesyRonaldo P. Macedo Jr.13h 54m$17 · $0.00
Understanding Soccer: A Guide to Playing, Watching, and Enjoying the Beautiful GameTavin D. Spicer4h 10m$3.50 · $0.00
VegetarianNaumann & Göbel Verlag3h 23m4.4 (15)$5 · $0.00
Prelude in Cm (Chopin)Bill Brown Jr.30m$2
History of SportsKenny Abdo17m$2
I'll See You in My DreamsBill Brown Jr.1h 5m$10
1000 essential words in AlbanianJM Gardner2h 18m$10 · $0.00
Guitar By Ear: Rock and Blues Box Set 4Bill Brown Jr.14h 43m$23
Lessons in Music Form (Annotated)Percy Goetschius5h 15m4.6 (16)$2 · $0.00
On Generation and CorruptionAristotle2h 58m3.5 (307)$1.80 · $0.00
How to Play Chess (Annotated)Charlotte Boardman Rogers2h 43m4.1 (12)$2 · $0.00