
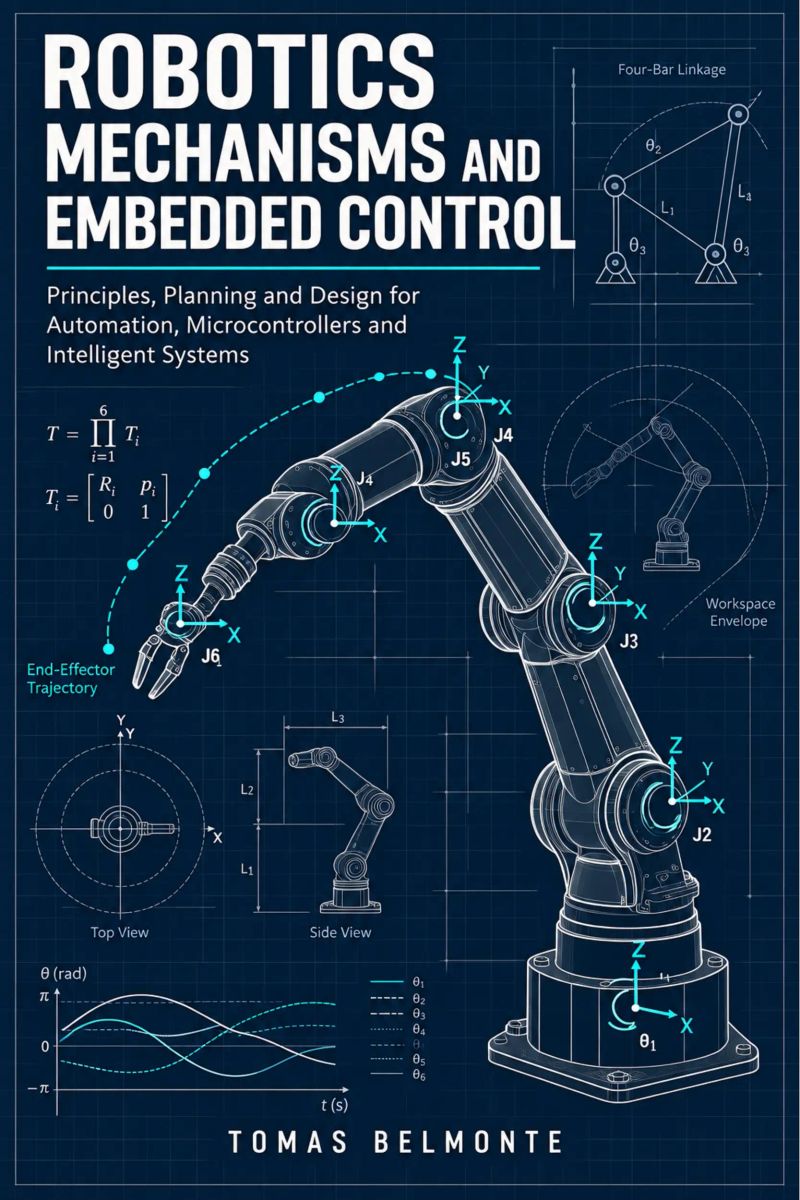
Robotics Mechanisms and Embedded Control
Principles, Planning and Design for Automation, Microcontrollers and Intelligent SystemsBy Tomas Belmonte


Length15h 11m
About this audiobook
A practical guide that unites robot mechanics and embedded control, from kinematics and drive sizing to PID loops and motion planning, with solved examples throughout.
Audiobook details
GenreTechnology
Length15 hrs 11 mins
Narrated byListen with 1,000+ voices
FormateBook with Audio
Publish dateSep 27, 2026
LanguageEnglish
Table of contents
1Robotics Mechanisms and Embedded Control
2Foreword
3Preface
4About This Book
5Important Safety Notice
Mostrar todos os capítulosVer menos
6Chapter 1: Rigid-Body Motion
71.1 Frames, Coordinates and the Pose of a Rigid Body
81.2 Rotation Matrices and Elementary Rotations
91.3 Composition, Euler Angles and Axis-Angle Representation
101.4 Homogeneous Transforms and Frame Chains
111.5 Twists, Screw Axes and Exponential Coordinates
121.6 Angular Velocity, Differentiation and the Transport Theorem
13Chapter 2: Mechanisms and Linkages
142.1 Links, Joints and Degrees of Freedom
152.2 Four-Bar Geometry and the Grashof Criterion
162.3 Slider-Crank and Scotch Yoke Mechanisms
172.4 Cam Profiles and Follower Motion
182.5 Gear Trains, Ratios and Backlash
19Chapter 3: Power Transmission and Drive Sizing
203.1 Belts, Chains and Rack-and-Pinion Drives
213.2 Ball Screws and Lead Screw Mechanics
223.3 Harmonic and Cycloidal Drives
233.4 Reflected Inertia and Gear-Ratio Matching
243.5 Torque, Speed and Duty-Cycle Sizing
25Chapter 4: Forward Kinematics
264.1 Kinematic Chains and Joint Variables
274.2 Denavit-Hartenberg Parameters
284.3 The Product-of-Exponentials Formula
294.4 Workspace, Reach and Dexterous Envelope
30Chapter 5: Inverse Kinematics
315.1 Existence, Multiple Solutions and Branch Selection
325.2 Closed-Form Solution by Geometric Decoupling
335.3 Numerical Inverse Kinematics by Jacobian Iteration
345.4 Workspace Limits and Joint-Limit Handling
35Chapter 6: Velocity, Statics and the Jacobian
366.1 The Jacobian Matrix and Velocity Propagation
376.2 Singularities and Manipulability
386.3 Static Forces and the Jacobian Transpose
396.4 Singularity Detection and Avoidance
40Chapter 7: Manipulator Dynamics
417.1 Mass Moments of Inertia and the Inertia Tensor
427.2 Recursive Newton-Euler Formulation
437.3 Lagrangian Formulation and the Standard Dynamic Model
447.4 Gravity Compensation and Friction Modeling
45Chapter 8: Actuators
468.1 Brushed DC Motor Model and Torque Constant
478.2 Brushless DC and Permanent-Magnet Synchronous Motors
488.3 Stepper Motors and Open-Loop Positioning
498.4 Servo Drives, Torque Constants and Thermal Limits
50Chapter 9: Sensors and Signal Conditioning
The Honey BusMeredith May9h 31m4.4 (16.6K)$25 · $0.00
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
Operation PedestalMax Hastings12h 29m4.4 (5.2K)$29 · $0.00
When the Heavens Went on SaleAshlee Vance18h 20m4.4 (3K)$40 · $0.00
Everybody Has a Podcast (Except You)Justin McElroy, Travis McElroy, Griffin McElroy5h 9m4.3 (2.3K)$24 · $0.00
Hands of TimeRebecca Struthers8h 8m4.4 (1.3K)$26 · $0.00
Never Lost AgainBill Kilday10h 1m4.4 (805)$29 · $0.00
How the Internet HappenedBrian McCullough13h 28m4.3 (2.7K)$23 · $0.00
Collected Writings of Nikola TeslaNikola Tesla, Thomas Commerford Martin21h 50m4.3 (1.7K)$1 · $0.00
Just AspireAjai Chowdhry9h 13m4.4 (260)$29 · $0.00
The Little Book of AliensAdam Frank8h 20m4.3 (1.3K)$26 · $0.00
The inventions, researches and writings of Nikola Tesla (Annotated)Thomas Commerford Martin16h 59m4.3 (1.3K)$2 · $0.00
KargilV.P. Malik15h 18m4.3 (2K)$24 · $0.00
Experiments with Alternating CurrentsNikola Tesla9h 16m4.3 (874)$1.99 · $0.00
Fire on the HorizonTom Shroder, John Konrad8h 23m4.3 (858)$26 · $0.00
The Smell of Kerosene (Annotated)National Aeronautics and Space Administration, Donald L. Mallick, Peter W. Merlin11h 32m4.3 (523)$2 · $0.00
The Boy Who Harnessed the WindWilliam Kamkwamba, Bryan Mealer10h 5m4.2 (78.9K)$29 · $0.00
Across the Airless WildsEarl Swift10h 8m4.3 (1.3K)$29 · $0.00
Console WarsBlake J. Harris20h 41m4.2 (13.7K)$46 · $0.00
Improvised Munitions HandbookU.S. Department of Defense4h 49m4.3 (1.6K)$0.99 · $0.00
You may also like
ITIL Foundation Essentials ITIL 4 Edition - The ultimate revision guide, second editionClaire Agutter1h 12m4.2 (462)$27 · $0.00
Pete the Cat: Robo-PeteJames Dean5m4.0 (2.3K)$4 · $0.00
Collected Writings of Nikola TeslaThomas Commerford Martin, Nikola Tesla19h 42m4.4 (2.8K)$1.99 · $0.00
AutonomyLawrence D. Burns, Christopher Shulgan11h 21m4.1 (1.1K)$29 · $0.00
C++ for RoboticsEsther Underwood7h 21m$5 · $0.00
Signal Processing for Electrical EngineersHelen Marchetti12h 6m$80
Python Robotics and Computer VisionVikram Dasgupta11h 11m$70
Machines at WorkMary Elting37m3.9 (18)$2 · $0.00
Artificial Intelligence for Workflow AutomationTheo Riven3h 25m$5
Edge-AI-Engineering Wie man Künstliche Intelligenz am Netzwerkrand Aufbaut, Bereitstellt und OptimiertSloane Garrett6h 33m$13 · $0.00
Control Systems Theory and AnalysisSanjay Khatri12h 6m$75
Neural Networks Without PythonPaloma Iqbal7h 29m$5 · $0.00
Master AiHenrique Xavier Oliveira2h 5m$6 · $0.00
Disturbance rejection control for bipedal robot walkersJaime Arcos Legarda4h 24m$7 · $0.00
Giant Brains, or, Machines That ThinkEdmund Callis Berkeley9h 21m$2.30
Computers The Machines We Think WithD. S. Halacy8h 40m3.5 (10)$2.30
Eft Investing: A Comprehensive Guide to Researching and Investing (The Intelligent Investor's Guide to Using Free Online Stock Screeners to Find Winning Stocks)Matthew Nagel2h 7m$3.50 · $0.00
FAA PART 107 DRONE STUDY GUIDE 2026/2027Adrian Hartwell10h 49m$10
DriverlessHod Lipson, Melba Kurman9h 57m3.9 (552)$20
The Artificial AuthorSimone Aliprandi7h 42m$15 · $0.00